Lecture Demos
Blindfolded Walk (Kalman Filtering)
A hands-on introduction to Kalman filtering, with no math required.
Originally prepared for a Physics Seminar at Southern Adventist University, 2026-10-01 6:00 PM, Lynn Wood Hall 3012.
The Problem
Imagine walking 12 feet in a straight line along a tape measure, blindfolded, and stopping exactly at three waypoints: 4 ft, 8 ft, and 12 ft.
You have one tool: your own sense of how far you've gone. You count your steps and guess how long each step is. That guess is never quite right, and the error adds up with every step.
This is the same problem faced by robots, self-driving cars, aircraft, and phones. They all have an internal "dead-reckoning" sensor that drifts, and an outside source that tells them where they are but is imperfect. Kalman filtering is a systematic way to blend the two so that the result is better than either one alone.
In this activity you will:
- Experience the drift of an internal sensor first-hand.
- See what an outside "aiding source" can do for you.
- Discover what happens when that aiding source is noisy, and learn how to decide how much to trust it.
What You Need
- A tape measure (at least 12 ft) taped flat to the floor
- A blindfold
- A wall or chalkboard running alongside the tape (see the safety and setup notes)
- Three custom dice (see below)
- Pencil and the recording tables at the end of this section
- Three volunteers: a Walker, a Companion, and a Recorder
The Three Dice
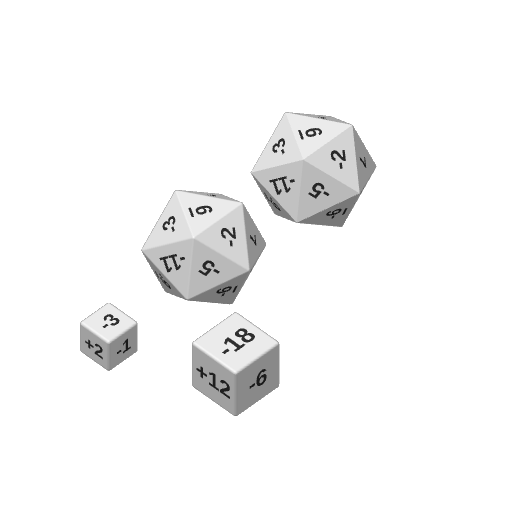
The dice are 3D-printed (white body, black labels). The label values are in inches. The Companion rolls one die each time they call out a position, and adds the roll to the true position before saying it out loud.
| Die | Faces | Typical error | Think of it as... |
|---|---|---|---|
| Die A (6-sided) | -3, -2, -1, +1, +2, +3 | about 2 inches | high-accuracy sensor |
| Die B (6-sided) | -18, -12, -6, +6, +12, +18 | about 12 inches | low-accuracy sensor |
| Die C (20-sided) | bell-curve values, mean 0 | about 6 inches | medium-grade, realistic sensor |
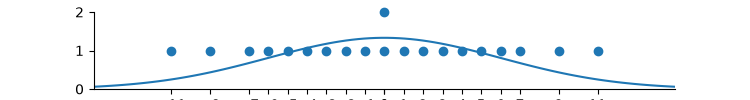
Files: STL and SCAD models of the dice and a time-lapse video of them printing are linked at the bottom of this page.
Setup and Safety
- Clear the walking lane completely. Nothing to trip on, and no one else in the path.
- The Walker keeps one hand lightly on the wall or chalkboard to stay a constant distance from it, so they walk straight alongside the tape.
- Important: the wall is only for staying in your lane. Do not use doors, corners, posters, wall features, or any other landmark as a position reference. You may not feel for "I passed the light switch." The only position information allowed is your own step estimate, and later, the Companion's voice.
- The Walker starts with their toes at 0 ft.
- The Companion walks alongside, watching the Walker's feet against the tape, and stays out of the Walker's way.
- Stop the walk immediately if anyone is uncomfortable. A spotter should be nearby.
The Experiment
The Walker's goal is the same in every run: stop at 4 ft, then 8 ft, then 12 ft. At each stop, the Recorder reads the true position off the tape and writes it down.
Step 1: Odometry Only
The Walker is blindfolded and walks, counting steps and using their best guess of step length. They say "stop" when they believe they are at a waypoint. No help from anyone.
What to notice: How far off were you? Did your error grow as you walked farther?
Step 2: A Perfect Companion
Repeat the walk, but now the Companion calls out the Walker's true foot position as they walk, as often as the Companion likes. The Companion's numbers are exactly right.
What to notice: Does the Walker's error stop growing? How does it feel to be corrected constantly?
Step 3: A Noisy Companion (Dice)
Now the Companion is no longer perfect. Before each call-out, they roll a die and add the result to the true position(rolling -6 means subtract 6 inches), then say the corrupted number aloud.
For example: true position is 5 ft 0 in, die shows +12, so the Companion calls out "6 feet." Another example: true position 8 ft 0 in with a -3 on Die A gives "7 feet 9 inches."
The Walker must decide, on every call: do I trust my own step count, or do I trust the voice?
The team picks which die to use. Try each one, and try mixing: for instance, Die A for the first waypoint, Die B for the second.
What to notice: With Die A, you can mostly believe the voice. With Die B, it can be better to lean on your own steps. Die C is in between. Where is your sweet spot?
Simulated Results
Before the live demo, we simulated the same walk on a computer to show what to expect. In the simulation, the Walker's steps are secretly 20% shorter than they believe, and the Companion's voice has about 1 foott of noise (the "wild" case).
Plot 1: Odometry alone
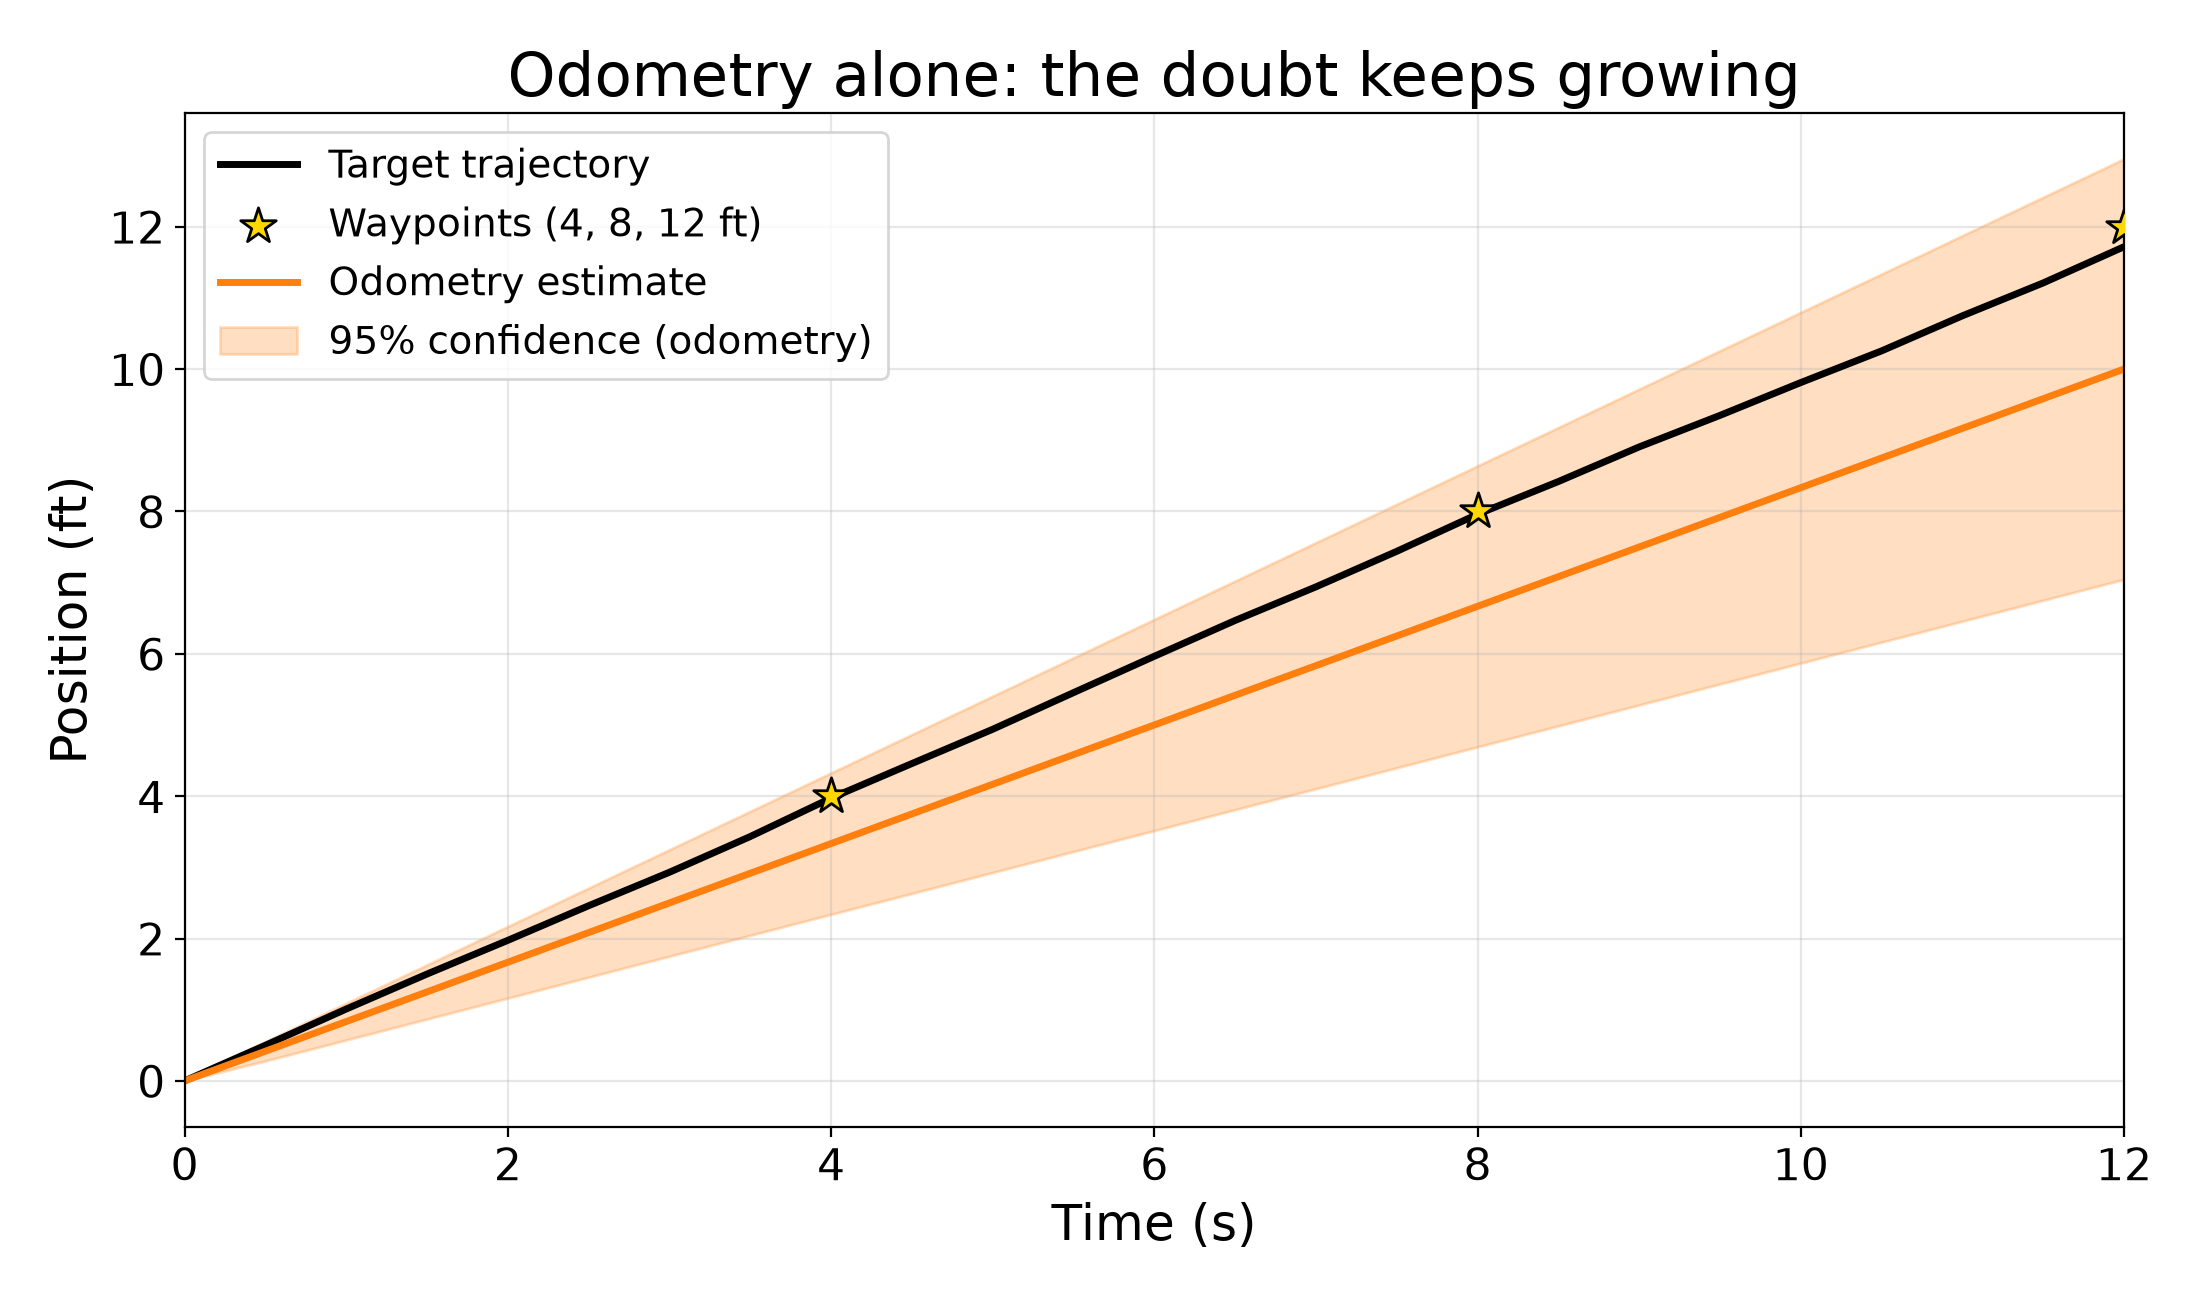
The orange line is the Walker's estimate. The shaded band is the 95% confidence interval: the zone where the true position probably lies, as far as the Walker can tell. Notice how the band keeps widening over time. The longer you walk on guesses alone, the less sure you should be.
Plot 2: The noisy voice alone
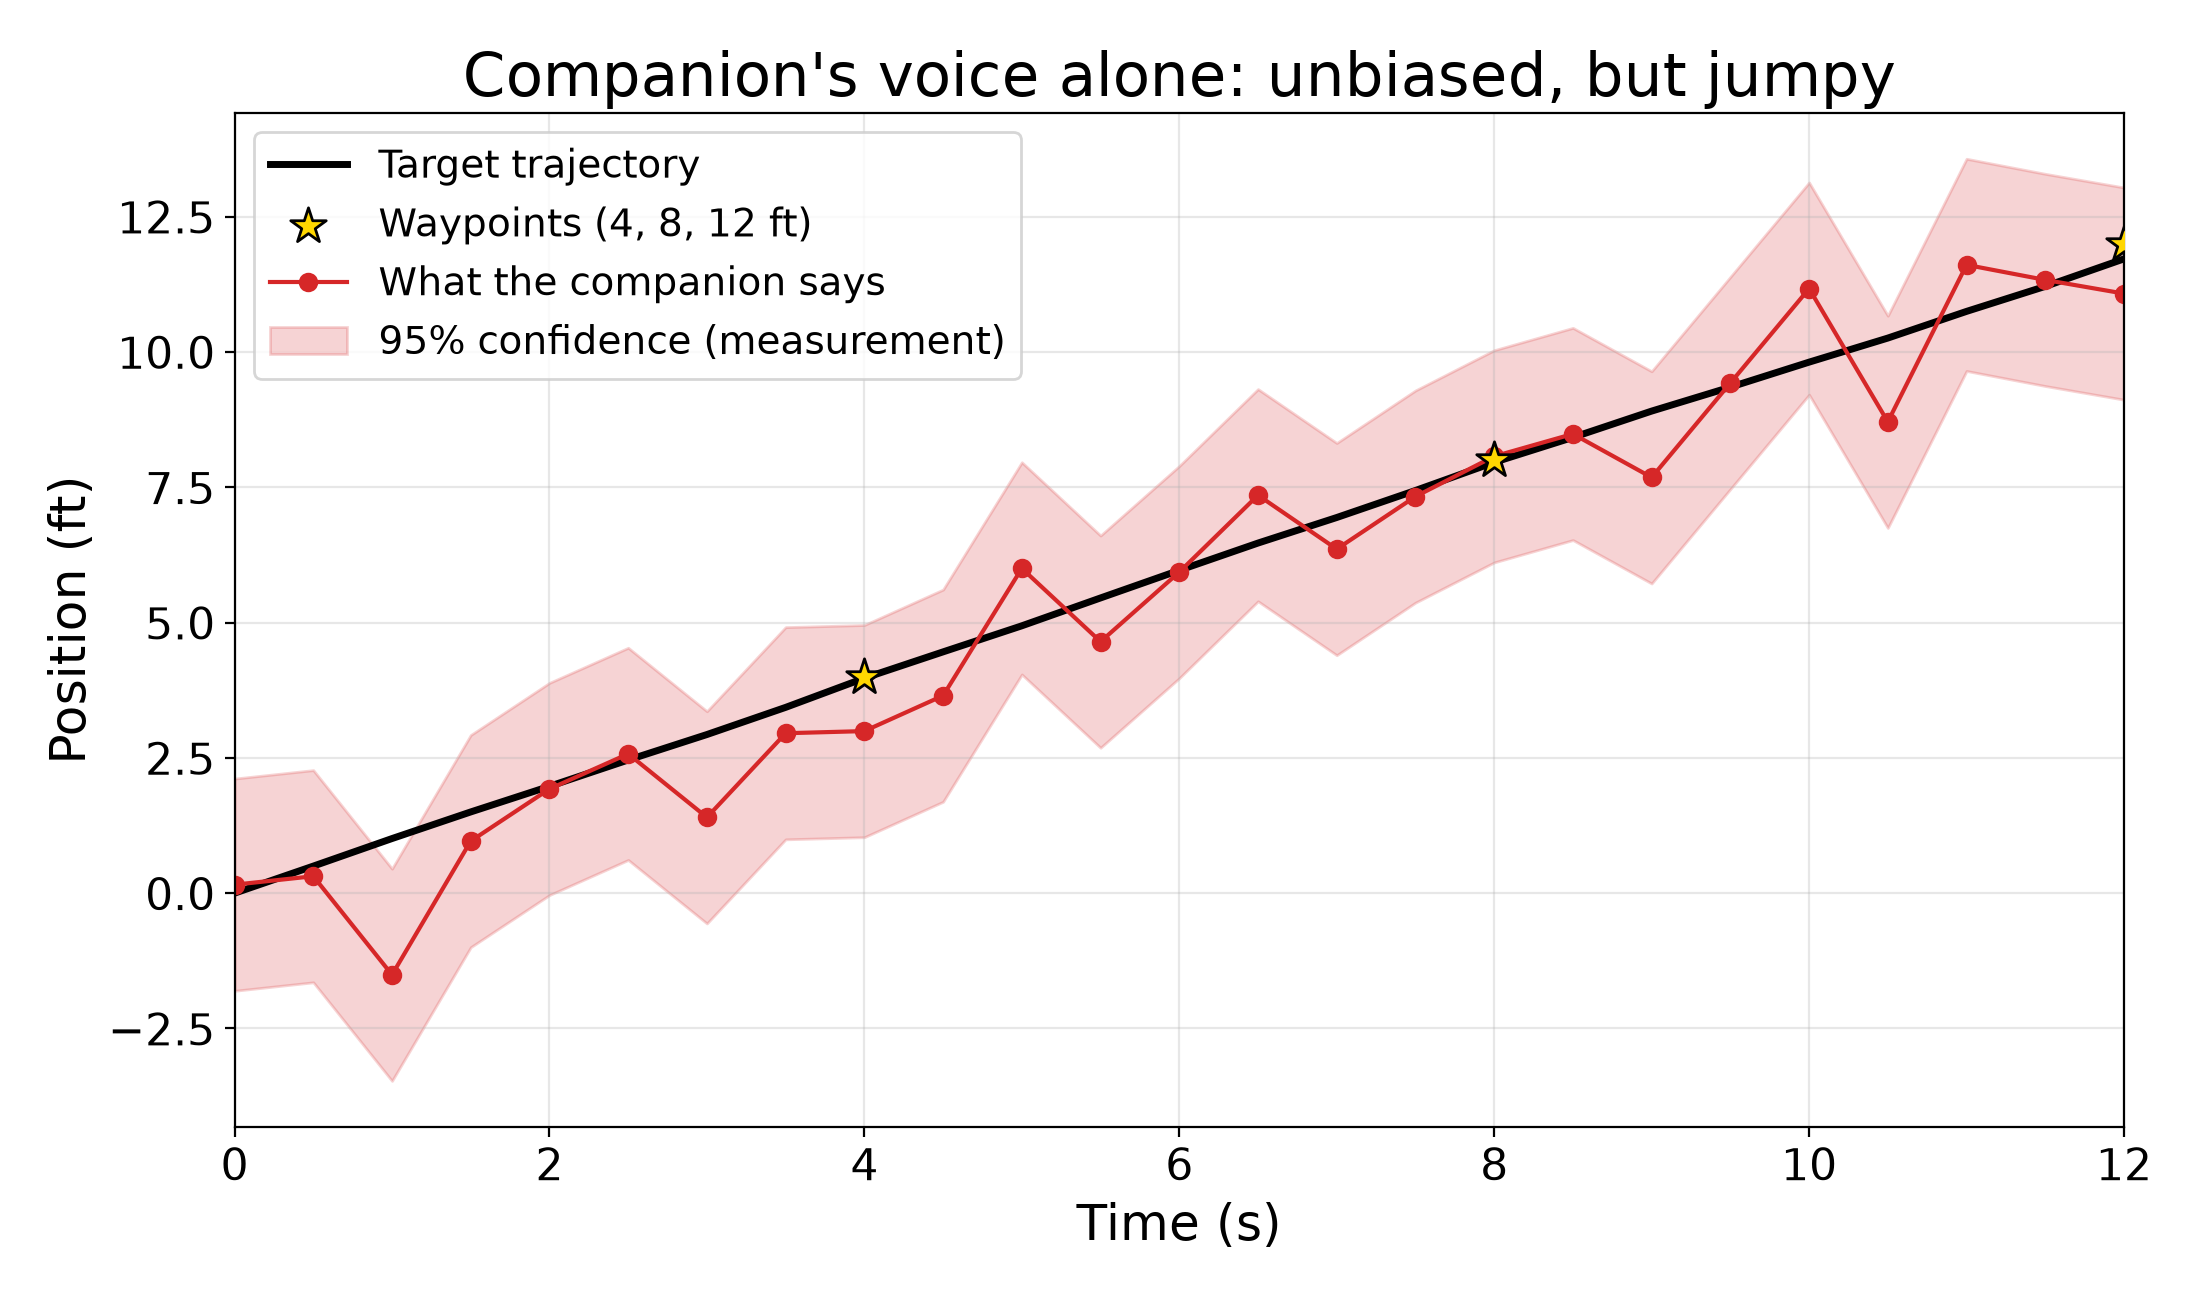
Each red dot is one call from the Companion. The calls are not drifting, since they are centered on the truth, but they jump around wildly from one call to the next. The band stays the same width at every moment.
Plot 3: Both together (the Kalman filter)
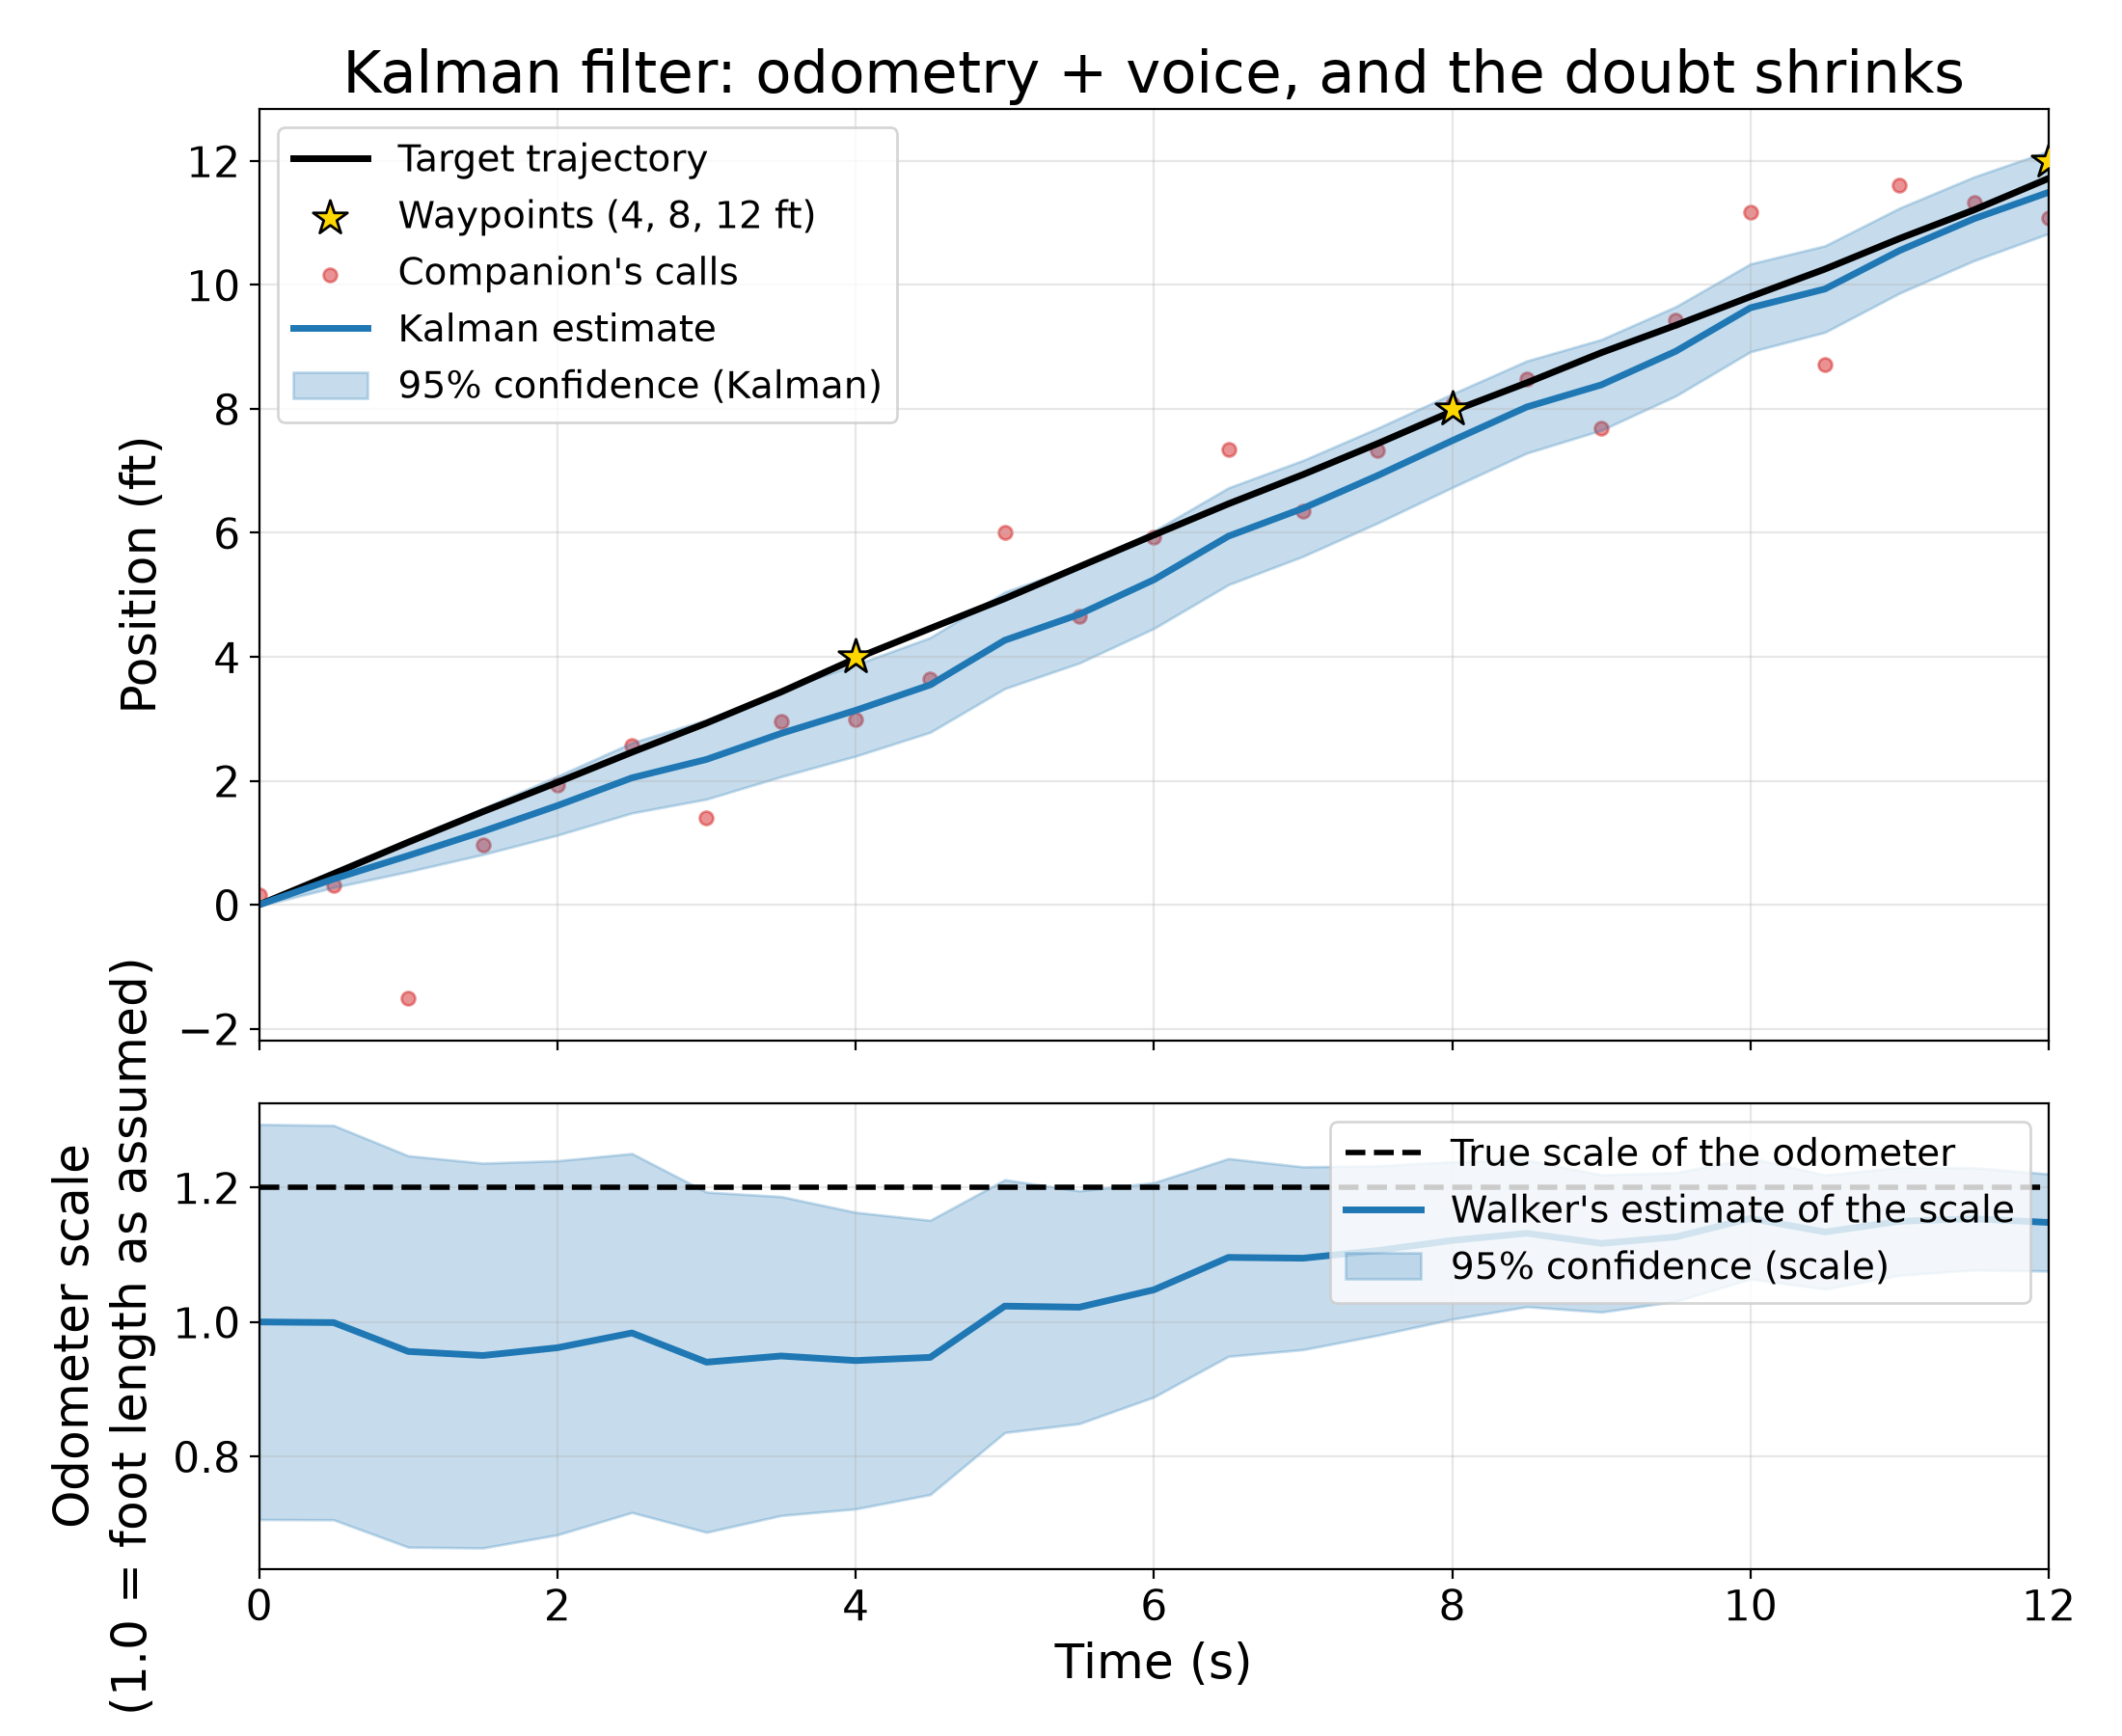
The blue line blends the Walker's steps with the Companion's calls. The top panel shows that the band is much tighter than either source alone. The bottom panel shows something extra: the Walker is also learning how wrong their step length is. The estimate of the foot length moves toward the truth, and the shaded uncertainty shrinks with every call.
The big idea: each source has weaknesses the other one covers. Odometry is smooth but drifts. The voice is jumpy but never drifts. Blended well, you get smooth and anchored.
Record Your Results
Read the true position off the tape at each stop. Use feet and inches.
Runs 1 and 2
| Waypoint | Target (ft) | Run 1: odometry only (tape reading) | Run 1 error |
|---|---|---|---|
| 1 | 4 | ||
| 2 | 8 | ||
| 3 | 12 |
| Waypoint | Target (ft) | Run 2: odometry only (tape reading) | Run 2 error |
|---|---|---|---|
| 1 | 4 | ||
| 2 | 8 | ||
| 3 | 12 |
Run 3: Noisy companion
| Waypoint | Target (ft) | Die used (A / B / C) | Tape reading | Error |
|---|---|---|---|---|
| 1 | 4 | |||
| 2 | 8 | |||
| 3 | 12 |
Optional log of every call (Run 3):
| Time (s) | True position | Die roll | What the Companion said | Did the Walker trust it? (yes / partly / no) |
|---|---|---|---|---|
Discussion
1. Why does your internal estimate drift?
List as many reasons as you can before reading further.
- Uncalibrated step length. You never actually measured your shoe/foot length while blindfolded, so every step carries the same small mistake, and those mistakes add up.
- Human error in foot placement. Each step lands a little short or a little long, in a way you can't feel.
- Not walking perfectly straight. Veering sideways means you travel farther than you think while making less progress along the tape.
- Losing count. Miscounting or skipping a step is a big, sudden error.
Notice the difference between errors that are the same every step (step length, which is consistent and can be learned) and errors that are random each step (foot placement). The Kalman filter in Plot 3 learns the first kind, and averages out the second.
2. What makes a good aiding source?
Think about the Companion and ask:
- Is it accurate? On average, is it centered on the truth? (Accuracy is about being right.)
- Is it precise? Does it give nearly the same answer each time? (Precision is about being consistent.) A source can be precise but wrong, or accurate on average but jumpy.
- Is it always available? Or does it drop out from time to time?
- What if the Companion has to leave? You fall back to odometry alone, and your uncertainty starts growing again. A good system should know its confidence is degrading.
- What if loud noise drowns out the Companion's voice? Calls are missing or garbled. A good Walker doesn't panic or guess wildly; they keep walking on odometry and expect their uncertainty to widen until the voice returns.
- What if someone who sounds just like the Companion starts calling out numbers? This is spoofing, and it's the most dangerous failure: a confident voice that is wrong. How could the Walker notice? One clue is a call that disagrees sharply with everything else they know. Another is having a second, independent source to cross-check.
Real-world parallel: GPS can be jammed (drowned out) or spoofed (faked). Systems that depend on it need a backup.
3. How much should you trust each source?
Discuss: when should you trust your own odometry, and when should you trust the Companion?
Some starting points:
- Right after you've been corrected, your own estimate is fresh and good. Lean on it.
- The longer it's been since a good correction, the less you should trust odometry.
- A precise Companion (Die A) deserves a lot of trust. A sloppy one (Die B) deserves a little.
- If a call is wildly different from what you expect, be suspicious of it, especially from a noisy source.
- Trust is not fixed. It should shift as the situation changes, and that is exactly what the Kalman filter does automatically at every step: it compares "how sure am I?" with "how sure is the sensor?" and weights them accordingly.
4. Proverbs 3:5-6
"Trust in the LORD with all thine heart; and lean not unto thine own understanding. In all thy ways acknowledge him, and he shall direct thy paths."
Proverbs 3:5-6 (KJV)
Reflection. The Walker's own internal sense of position is real and useful. But when they rely only on their own understanding, the error quietly grows, and they can't see it.
- Leaning not on our own understanding. The odometry-only plot shows what happens when we depend on ourselves alone. The uncertainty widens every step, even though it never feels that way.
- Trusting a reliable guide. In Run 2 the Companion is perfectly reliable, and the Walker's error stops growing. The question of the whole activity is how trustworthy is the source I'm listening to? With a noisy or spoofed voice, trust must be matched to reliability. The verse points to a source that, unlike our dice, is entirely trustworthy.
- Acknowledging in all our ways, and He shall direct thy paths. The Kalman filter doesn't ask for a correction once; it takes in a correction at every single step. Staying in constant contact with a trustworthy guide, rather than checking in only once in a while, is what keeps the uncertainty small.
Questions for discussion:
- In what areas of life do we rely on "odometry" (our own judgment) and drift without noticing?
- How do we decide which voices deserve trust, especially when several sound confident?
- What does it look like to stay in regular contact with a trustworthy guide, rather than only checking in occasionally?
Files and Media
- Dice models: MakerWorld
- Dice models (SCAD, parametric): 6-sided dice, icosahedron
- Jupyter notebook to generate graphs: blindfolded-kalman-filter.ipynb